Evaluate the delta, elevate the data
Small gaps in requirements can become big differences in AI data
The robot hand must be in frame.


A robotic hand includes the end-effector or gripping mechanism, with explicitly defined boundaries for fingertips, grippers, hand assemblies, and wrist components.
Specify whether the entire target object must remain within the image boundaries, whether partial inclusion is acceptable, and whether any minimum spatial margin is required.
Establish the minimum required visibility of the target object and determine whether partial occlusion by other objects is acceptable.
Specify how exceptional conditions, such as gloves, unusual gripper designs, visual obstruction, camera distortion, or uncertain object boundaries, should be handled.
Small gaps in requirements can become big differences in AI data
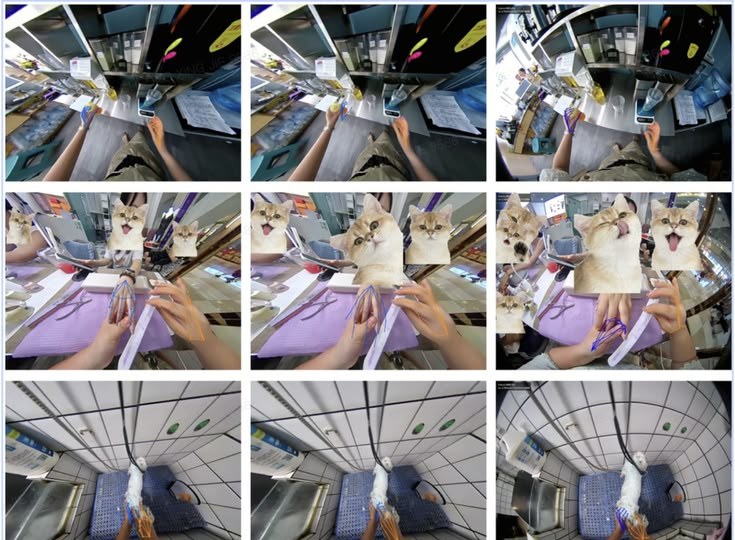 Data collection · RoboticsFrom staged footage to real workStaged footage kept stalling at review, so we captured real people doing real work.
 AI evaluation · Physical AIRanking physical AI video models with human judgmentA dozen generated videos per task. Which one behaves most like the real world?
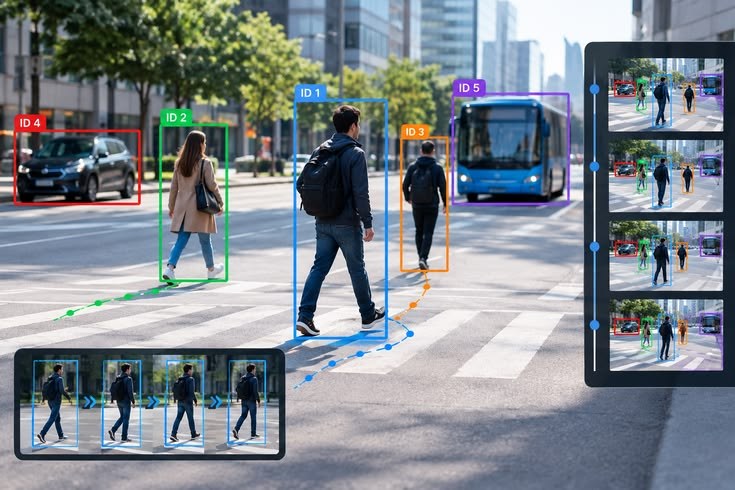 Annotation & QA · Computer visionScoping frame-level object trackingBefore pricing “track one object,” we defined what that sentence meant and tested the tools.
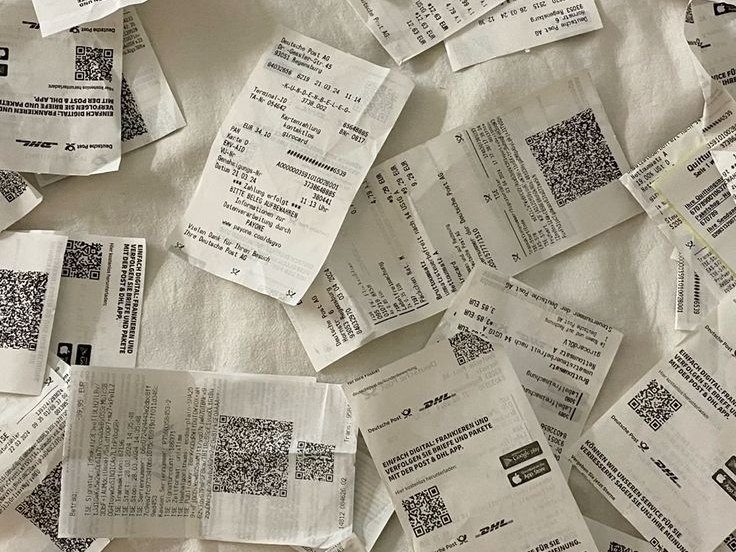 Data collection · Document AICollecting real purchase receipts, with consentReal receipts from real people, because synthetic samples were not acceptable.
Tell us what you’re working with. Many projects combine more than one of these.
Validate the approach, review the data, and align on quality before scaling.
Vieva is based in Hanoi and serves international AI teams.
Share the project, the data type, and your expected timeline.
Start a Project